Hugo Pousseur
Here you'll find my projects and scientific articles, mainly focused on autonomous vehicles, robotics and AI. Feel free to explore, and don't hesitate to reach out!

Research areas
Selected projects
All projects →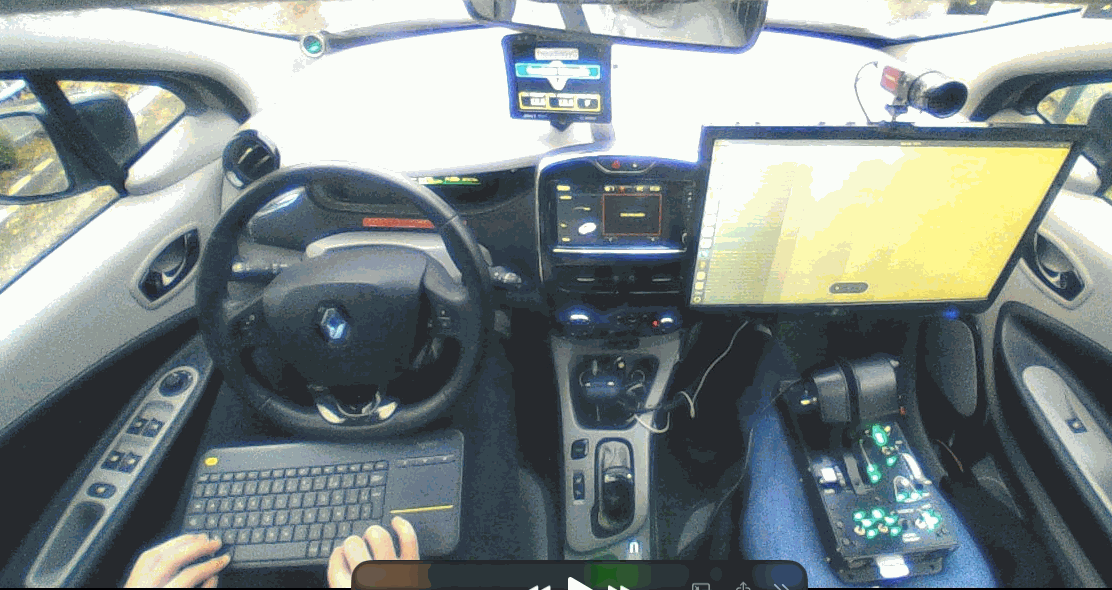 10 Nov 2025
Autonomous Vehicle: Teleop
Longitudinal control by teleop.
 14 Oct 2025
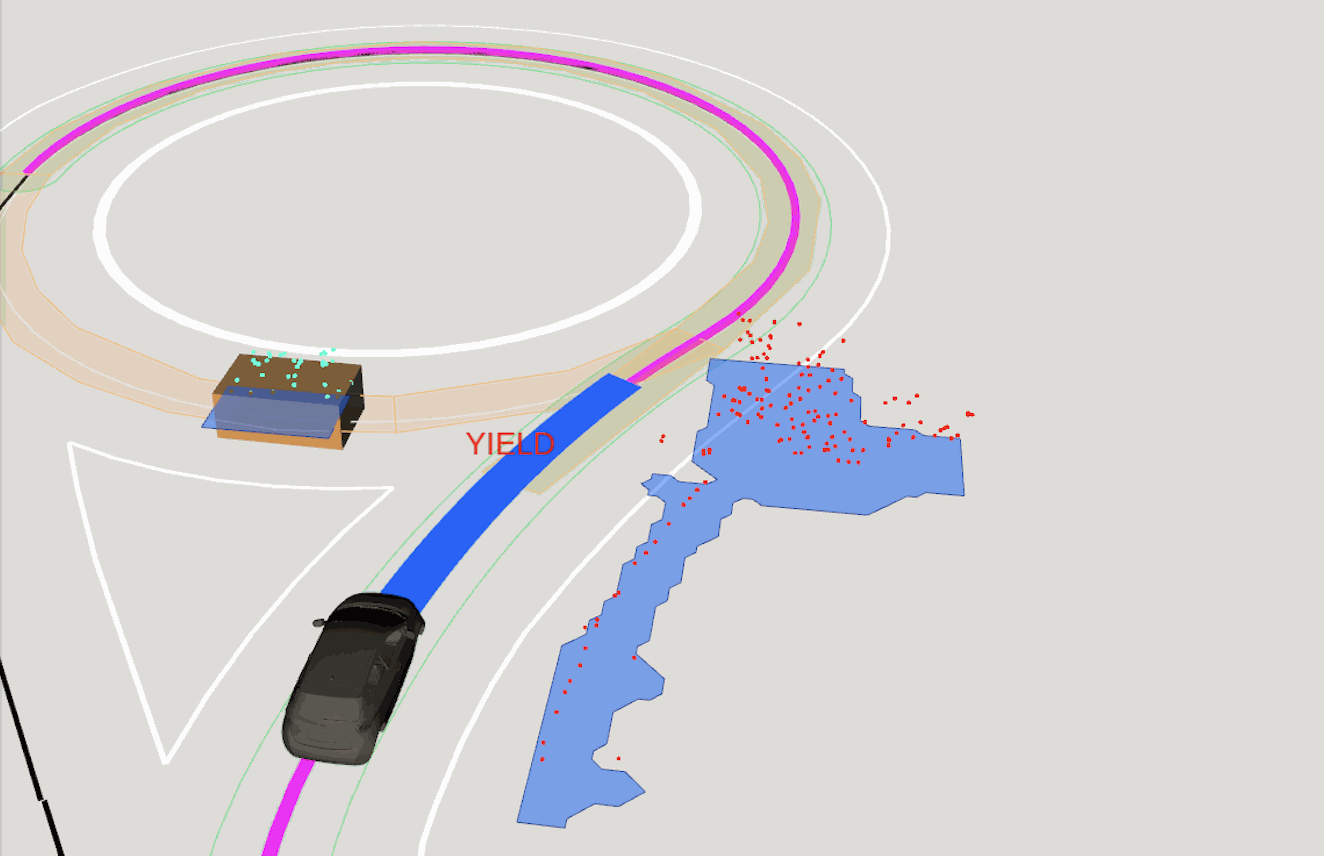
LiDAR Detection & Decision Making
Modular LiDAR perception pipeline for autonomous driving, built with ROS2 and configurable geometric clustering.
 15 May 2025
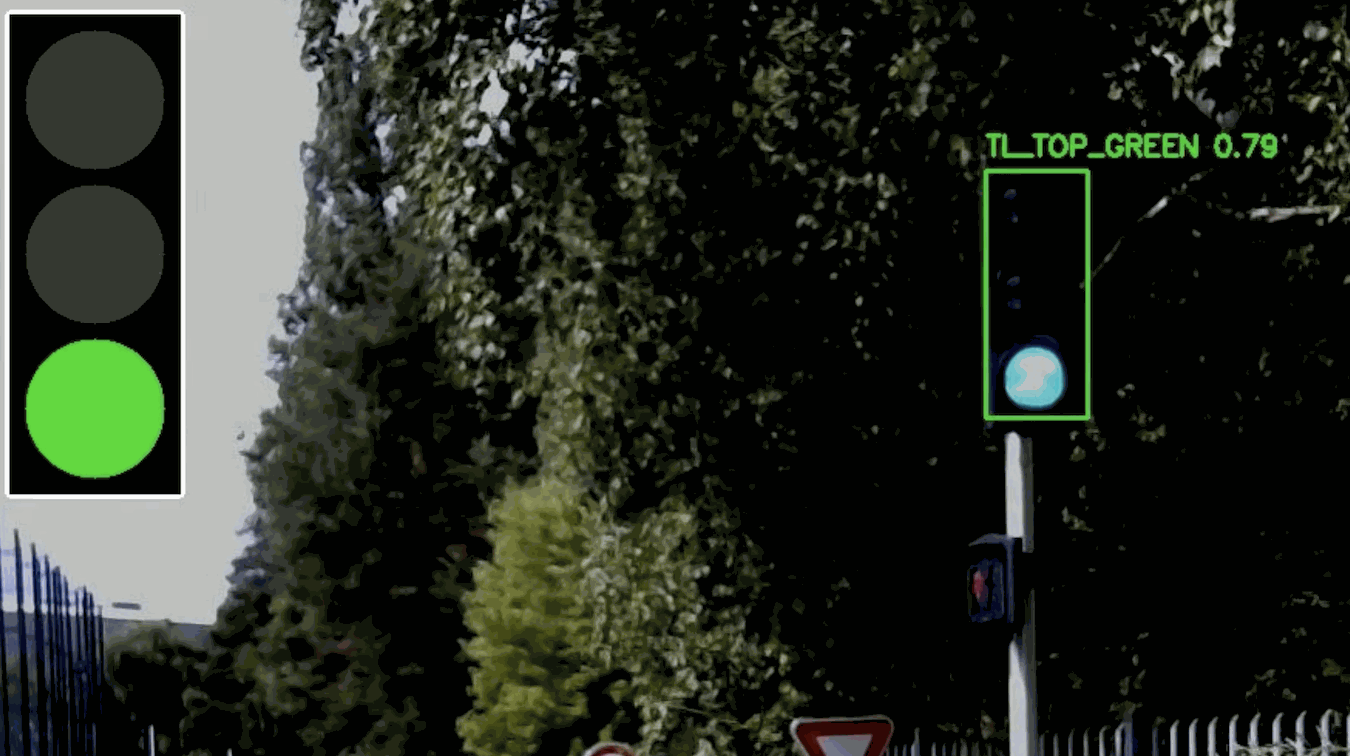
Traffic Light Detection & Control
Detection of traffic lights, and adaptation of vehicle control depending on the light state.
Latest from the blog
All posts →Why tmux Keeps Your Process Alive Over SSH: Process Trees, SIGHUP and a Client/Server Socket
What a process is attached to, what really kills it when an SSH connection drops, and how tmux avoids that with a server detached from your terminal and a client that talks to it through a Unix socket.
Xenomai: What It Is and How It Differs from Other Real-Time OSes
A map of the ways to get real-time behavior (tuned Linux, PREEMPT_RT, RTOSes, co-kernels), the limit of each one, and where Xenomai and its dual-kernel approach fit.
How ROS 2 Builds and Links Packages: Inside colcon, ament and CMake
What really happens between `colcon build` and a running node: package discovery, build ordering, CMake targets, the ament index and the Linux dynamic loader.
GitHub activity
@PouceHeure →Thesis: Shared navigation in a cybernetic multi-agent autonomous system
Latest videos
Teleoperation Demo. (Train Demo)
Video demo of the LiDAR Detection pipeline
Demo video: autonomous vehicle adapting control based on traffic light detection.